
Product Description
The Rexroth Indramat MKD090B-047-KP1-KN is a permanent-magnet synchronous servo motor from the MKD series, developed for precision motion control in industrial automation, machine tools, and automated production equipment. It features a 090 motor frame size, B-length housing, and 047 winding configuration. The motor incorporates resolver feedback with an integrated multiturn absolute encoder, a keyed shaft with sealing ring, and an 11 Nm holding brake. Its standard housing and terminal-box connection support integration into compatible Rexroth Indramat drive systems. The motor is identified by Bosch Rexroth part number R911263158 and should be matched with the installed drive controller, feedback interface, motor cable, and mechanical load before commissioning.
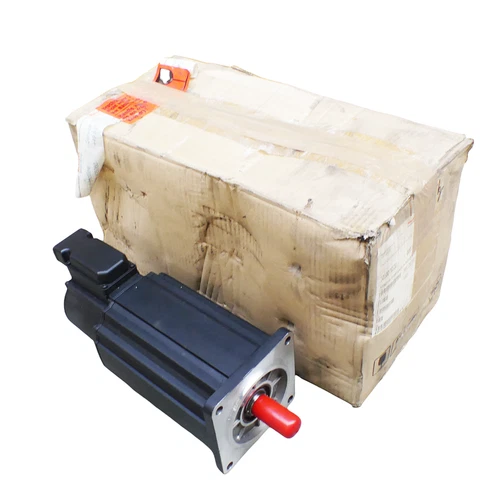
Product Datasheet
- Brand: Bosch Rexroth Indramat
- Product Series: MKD Synchronous Motors
- Model: MKD090B-047-KP1-KN
- Manufacturer Part Number: R911263158
- Product Type: Permanent-magnet synchronous servo motor
- Motor Frame Size: 090
- Motor Length: B
- Winding Code: 047
- Feedback: Resolver with integrated multiturn absolute encoder
- Position Detection: Multiturn absolute, more than 4,096 revolutions
- Shaft Design: Keyed shaft according to DIN 6885-1
- Shaft Sealing: Integrated shaft sealing ring
- Holding Brake: Integrated holding brake
- Holding Brake Torque: 11 Nm
- Holding Brake Supply: 24 VDC
- Holding Brake Current: 0.71 A
- Continuous Torque at Standstill: 12 Nm
- Rated Speed: Configuration-dependent; verify the motor nameplate and official data sheet
- Maximum Speed: Up to 4,500 rpm, subject to operating conditions
- Cooling: Verify exact cooling arrangement against the nameplate and motor documentation
- Housing Design: Standard
- Electrical Connection: Terminal box, output direction side B
- Protection Rating: IP65
- Centering Diameter: 110 mm
- Weight: Approximately 14–17 kg; verify the actual motor configuration
- Condition: Subject to seller confirmation
- Country of Origin: Not verified
Operating Guidelines and Usage
- Verify the motor type code and R911263158 part number against the machine’s original motor specification.
- Confirm compatibility with the installed Rexroth Indramat drive controller and power supply.
- Check the motor’s winding code, rated current, torque, and speed requirements before connecting it to the drive.
- Verify that the feedback interface supports the integrated multiturn encoder.
- Inspect the keyed shaft, sealing ring, mounting flange, and terminal box before installation.
- Confirm that the coupling, gearbox, and driven machine are correctly aligned.
- Connect the motor power cable, feedback cable, protective earth, and holding-brake wiring according to the wiring diagram.
- Ensure that the holding brake is controlled by the approved drive or brake-control circuit.
- Perform motor identification and commissioning checks using the compatible Rexroth drive configuration tools.
Power-On and Power-Off Sequence
Power-On
- Inspect the motor housing, shaft, connectors, and mounting hardware.
- Verify the power cable, feedback cable, protective earth, and brake connections.
- Confirm that the motor is mechanically coupled and that the driven equipment can move safely.
- Energize the drive system according to the controller manufacturer’s startup procedure.
- Check encoder feedback and motor identification data.
- Verify the holding-brake release sequence before enabling motion.
- Perform a low-speed test and confirm correct rotation direction.
- Return the axis to normal operation only after drive diagnostics and positioning checks are satisfactory.
Power-Off
- Stop the machine and bring the motor to a controlled standstill.
- Disable the servo drive using the approved machine procedure.
- Apply the holding brake through the designated control circuit where required.
- Switch off and isolate the drive power supply.
- Allow the drive DC bus to discharge according to the controller manufacturer’s instructions.
- Verify that hazardous voltage is absent before disconnecting motor or feedback cables.
- Secure the motor and driven mechanism before performing mechanical maintenance.
Normal Operating Procedure
- Monitor motor current, torque demand, speed, and drive temperature during operation.
- Check encoder feedback and position-control performance for abnormal deviations.
- Listen for unusual bearing noise, vibration, or mechanical resonance.
- Monitor holding-brake operation during stop and power-loss conditions.
- Keep the motor surface and cooling areas free of accumulated dust and contamination.
- Inspect the shaft seal and mounting flange for signs of oil or moisture ingress.
- Avoid operating beyond the motor’s rated torque, current, and speed limits.
- Record drive alarms and operating conditions to support preventive maintenance.
Parameter Settings and Modification
The MKD090B-047-KP1-KN is a servo motor whose operating characteristics are configured through a compatible Rexroth Indramat drive controller.
Before modifying parameters:
- Confirm the complete motor type code and winding configuration.
- Select the correct motor data in the drive commissioning software.
- Verify encoder type and multiturn position feedback settings.
- Set current, speed, torque, and acceleration limits according to the motor and machine specifications.
- Configure the holding-brake control sequence and verify the brake’s 24 VDC supply.
- Check motor rotation direction and feedback polarity during commissioning.
- Back up the existing drive parameters before making changes.
- Do not substitute motor data from another MKD090 winding or encoder configuration without checking the manufacturer’s documentation.
Maintenance and Troubleshooting
Preventive Maintenance
- Inspect the motor housing and mounting flange for damage.
- Check the shaft seal for leakage, contamination, or wear.
- Inspect the keyed shaft and coupling for looseness or mechanical damage.
- Check power and feedback connectors for corrosion or loose contacts.
- Verify holding-brake operation during scheduled maintenance.
- Monitor motor temperature, vibration, and bearing noise.
- Maintain records of motor operating hours, alarms, and maintenance activities.
Troubleshooting
- Motor does not start: Check drive enable status, power connections, controller interlocks, and motor configuration.
- Encoder or feedback fault: Inspect the feedback cable, connector, encoder configuration, and drive compatibility.
- Motor overcurrent: Check winding configuration, motor cable condition, mechanical load, and drive current settings.
- Motor overheating: Check operating load, cooling conditions, ambient temperature, and drive parameters.
- Holding brake does not release: Verify the 24 VDC brake supply, brake wiring, and control sequence.
- Positioning errors: Check encoder feedback, coupling alignment, mechanical backlash, and drive tuning.
- Abnormal vibration or noise: Inspect bearings, shaft alignment, mounting bolts, and the driven machine.
Motor disassembly, brake repair, and feedback-system testing should be performed by qualified personnel using approved service procedures.
Safety Precautions
- Servo motors must be operated with a compatible drive controller and correctly configured motor data.
- Isolate the drive power supply before disconnecting motor or feedback cables.
- Verify DC bus discharge before touching drive-system electrical connections.
- Secure the driven mechanism before releasing or servicing the holding brake.
- Do not rely on the motor holding brake as the sole personnel-safety device.
- Observe electrostatic discharge precautions when handling feedback connectors.
- Do not exceed the motor’s specified torque, current, speed, or temperature limits.
- Follow Bosch Rexroth documentation and the machine manufacturer’s electrical and mechanical safety procedures.
Recommended Related Rexroth Indramat Models
The following models are related MKD synchronous servo motors with comparable frame sizes or configuration options. They are not guaranteed drop-in replacements for R911263158. Confirm winding, encoder, shaft, brake, connection, and drive compatibility before ordering.
- MKD090B-047-KP1-KS – MKD090B servo motor, alternate housing configuration
- MKD090B-047-KP2-KN – MKD090B servo motor with alternate holding-brake configuration
- MKD090B-047-KP2-KS – MKD090B servo motor, alternate brake and housing configuration
- MKD090B-058-GG0-KN – MKD090B servo motor, 058 winding, resolver feedback
- MKD090B-058-GG1-KN – MKD090B servo motor with holding brake
- MKD090B-058-GG2-KN – MKD090B servo motor with alternate holding-brake configuration
- MKD090B-058-GP0-KN – MKD090B servo motor with keyed shaft
- MKD090B-058-GP0-KS – MKD090B servo motor, alternate housing configuration
- MKD090B-058-GP1-KN – MKD090B servo motor with keyed shaft and holding brake
- MKD090B-058-KG0-KN – MKD090B servo motor with multiturn absolute encoder
- MKD090B-058-KG1-KN – MKD090B servo motor with multiturn encoder and holding brake
- MKD090B-058-KG2-KN – MKD090B servo motor with alternate brake configuration
- MKD090B-058-KP0-KN – MKD090B servo motor with multiturn encoder and keyed shaft
- MKD090B-058-KP1-KN – MKD090B servo motor with multiturn encoder, keyed shaft, and holding brake
- MKD090B-058-KP0-KS – MKD090B servo motor, alternate housing configuration


